A 2023 study in the journal Biomimetics summarizes the challenges of remote Explosive Ordnance Disposal (EOD) for human teleoperators. “In an EOD scene, an operator is usually in a state of high mental stress due to the need to constantly pay attention to the state of operating tools and suspicious objects,” the authors write. They add that the counterintuitive nature of joysticks and buttons requires more training (and cognitive load) for the human operator.
The factors leading to teleoperator failure have been studied for decades. In 2004, when Jennifer Carlson and Robin Murphy analyzed field logs from rescue and inspection robots, they found human failures occurring roughly once every 17 minutes of robot use. Mechanical failures, by comparison, arrived every 24 hours. It is only now, with the great leaps in reinforcement learning and imitation learning, that we are in a position to combine what we know about haptics with much smarter robot models. We believe Minerva Humanoids is well positioned to pursue this opportunity.
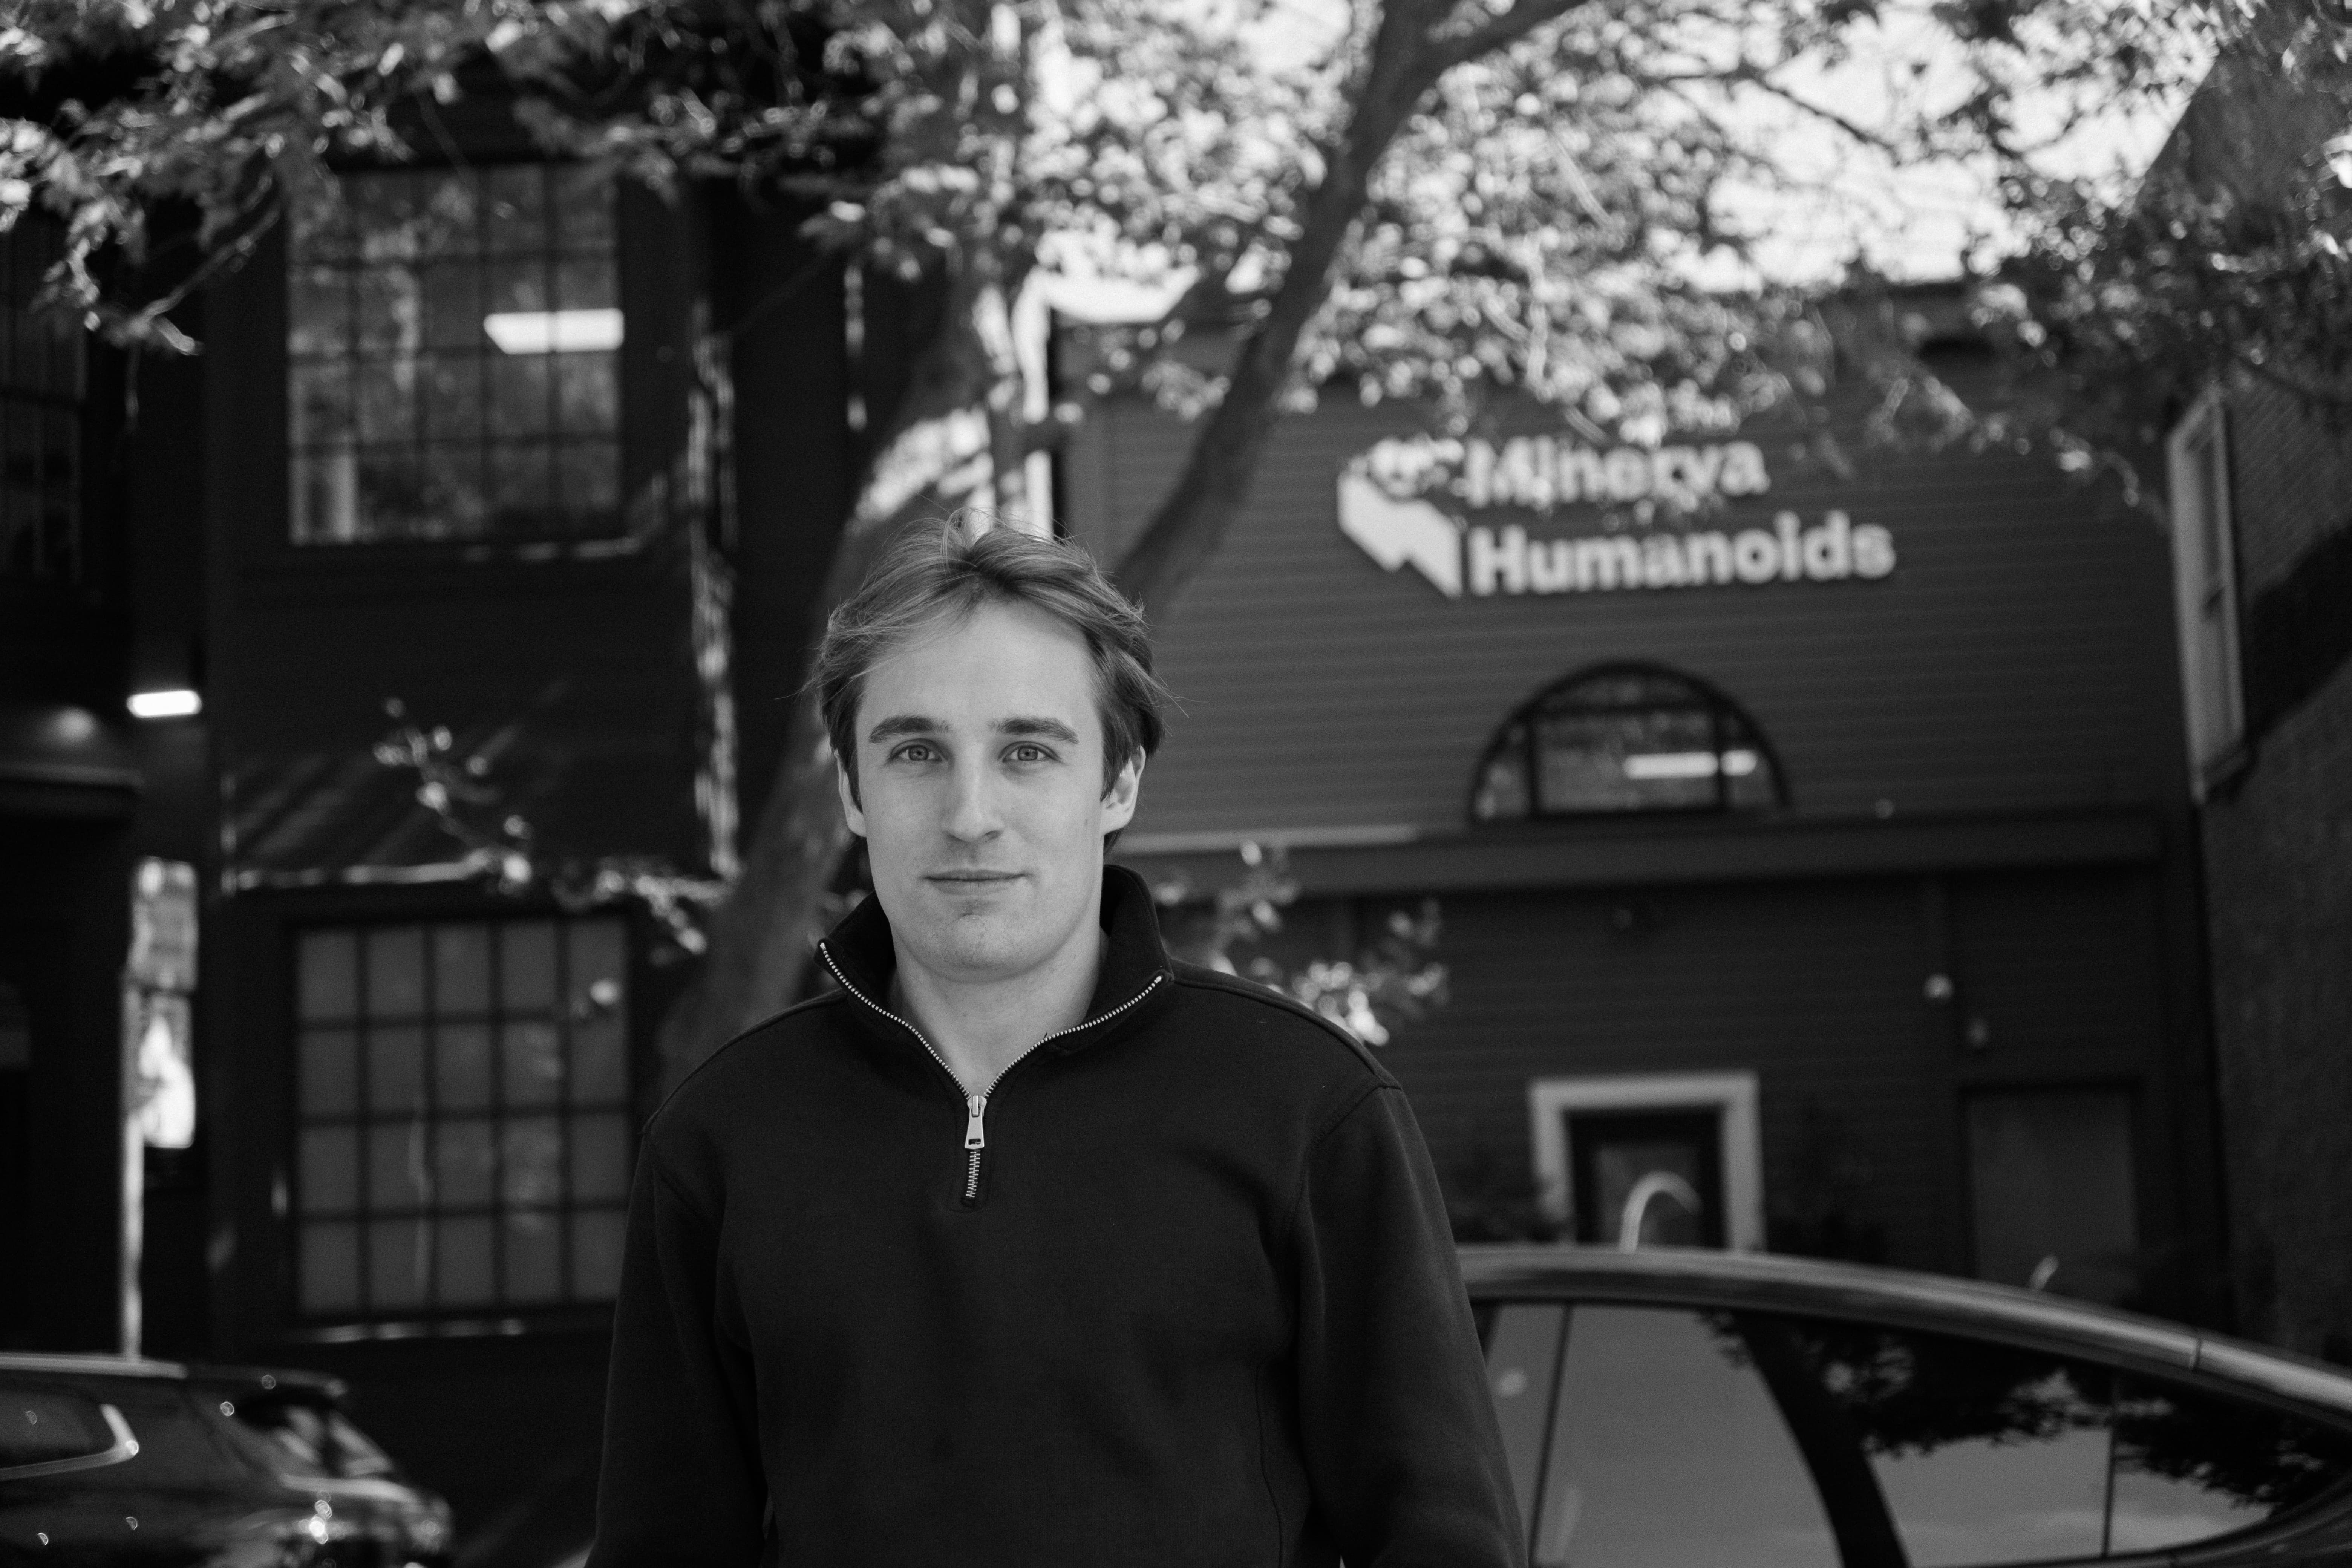
Sandor Felber, cofounder of Minerva, fell in love with electrical and mechanical engineering while racing and building the UK's top driverless electric car as a hobby project at Edinburgh University. Sandor spent a year at UCLA and then he went to work for Tesla. “At Tesla I really experienced what it's like to live in an engineering paradise,” Felber says.
While other robotics founders tackle domestic tasks and chores, Felber is looking at challenges like EOD in addition to medical care in the danger zone (like applying a tourniquet remotely on a battlefield in Ukraine) and high risk tasks in the oil and gas industry. “Humanity has spent enormous ingenuity teaching robots to make coffee, deliver parcels and perform athletic demonstrations; and made great strides. Minerva is asking a different question: what if we pointed some of the best robotics engineering in the world first at the jobs where human beings are most likely to be killed or maimed?” asks Alan Brown, Minerva’s strategic advisor and a former Commanding Officer of a British Army bomb disposal regiment.
“What if we pointed some of the best robotics engineering in the world first at the jobs where human beings are most likely to be killed or maimed?”
Minerva's answer is Roger, a humanoid prototype that walks up to the device so bomb technicians don't have to.
“Every EOD operator knows the long walk. When the robot can't complete the task and the operator has to put the EOD suit on and approach the device alone,” says British Special Forces veteran and Head of Hazardous Operations at Minerva Humanoids, Dominic Asquith. “The tracked, single-arm systems we've relied on for decades send a lot of people on that walk because the task needs two hands and real dexterity. Roger is a step-change for our community: the operator's judgement and hands are on the device while their body stays in the safety of the command post. I'd have wanted this on every deployment I did.”
Roger is also purpose-built for extreme offshore operations. It's humanoid because the rigs were designed for humans.
Advanced robotics is inherently an issue of national security and Minerva believes that a nation’s critical infrastructure will run on robots built domestically. The company endorsed the GUARD Act, bipartisan House legislation that would put humanoid and quadruped robots from China and other adversary nations on the FCC's Covered List unless cleared by US national security agencies, the same treatment given to Huawei and DJI. “In humanoid robotics the decisive years are now, while the supply chain is still being decided,” Felber says in the endorsement. Minerva backs equivalent protections in Germany and the EU to shield Europe's industrial economy, and its own plan follows the same logic.
Below is a condensed conversation between Robin Dechant and Minerva cofounder Sandor Felber.
The Conversation
Robin: Let's start at the beginning. You're European, building between Europe and the US right now. What was the path that led to you building robotics?
Sandor: I was lucky enough to do a full exchange year in the US during my undergrad at UCLA, so I spent a year living and studying in Los Angeles. After that, I spent some time at Tesla in the Valley, which was also a pretty formative experience.
Robin: Was Tesla the first time you were working on robots?
Sandor: That was the first time I was 100% working on a robot as part of a proper job, but I'd worked on robots in academia before, and as hobby projects, including designing, racing and building the UK's top driverless electric race car. You’d be surprised that what we're doing now isn't all that different from building race cars.
The LiDAR company that sponsored my team then has grown into the leading LiDAR company in the Western world, and we still use them. A lot of that technology is being developed in Edinburgh. My life story is a bit of a back-and-forth between the US and Europe. But if you want to be on the bleeding edge of tech, you have to move between different environments.
Robin: When you were at Tesla, was it clear to you then that you wanted to dedicate your working life to robotics and start a company?
Sandor: I really experienced what it's like to live in an engineering paradise: I had my own material sourcers, I didn't have to deal with any of the boring paperwork side of engineering, and at the same time we got to design some of the most groundbreaking systems in the world. That was back in 2022. Humanoids are ambitious today, but four or five years ago they seemed a lot more farfetched.
What led me to want to leave Tesla was that there wasn't much recognition at the time for AI-driven controllers, and I wanted to see what they could do. Boston Dynamics spent the better half of the last century focused on getting model-predictive control to work, and we've seen some amazing demos. Then there's been new developments in robotics through reinforcement learning and imitation learning: getting data from the real world or from a simulated environment and applying what you learn from that data to your system. We call that data-driven, or learning-based, control. I had the chance to dive into that at MIT a couple of years after Tesla, thanks to the experience I'd built at Edinburgh University.
Robin: When we first met, I was struck by your very strong opinion on the mission, ie. taking humans out of dangerous jobs. You haven't worked in bomb disposal or on an oil and gas rig yourself, so where does that conviction come from?
Sandor: I haven't, but a lot of the people around me have. One of my close friends from high school and college worked offshore after graduation and I couldn’t reach him for weeks at a time.
He told me about this gnarly experience of getting the safety training, where he was strapped into a helicopter and submerged underwater in a controlled environment, a swimming pool with safety divers on the side. He had to demonstrate that he could break through the window of the submerged helicopter and swim out. I thought, that doesn’t sound like something we’d want to put a lot of humans through. Ideally, we could automate some of that risk with humanoids.
I also met one of our strategic advisors, Al Brown, through mutual friends. He led the UK Ministry of Defense's study on AI and robotics and their impact on conflict, and before that he was in bomb disposal—he led a lot of the counter-IED teams in Afghanistan. He was a big inspiration too, in starting to support people who are really risking their lives for our safety and for energy.
Robin: You develop the software mostly in the US, but the hardware in Germany. How did you decide to do it that way?
Sandor: We were constrained by regional strengths and weaknesses. The startup ecosystem and the AI ecosystem here in San Francisco are incredibly strong, so it makes sense for us to develop our core intelligence stack in the US.
At the same time, what we found lacking in the US is the precision manufacturing industry, the kind that's really required for robots to be deployed in oil and gas and CBRN environments. Robots are this weird in-between of a car and a smartphone: you need the precision of a smartphone, but you need to bear loads similar to a car, mechanically speaking.
Robots are this weird in-between of a car and a smartphone: you need the precision of a smartphone, but you need to bear loads similar to a car, mechanically speaking.
Traditionally, the German automotive and industrial OEM ecosystem has been incredibly strong. A lot of American robotics has been powered by German-made actuators and manufacturing over the last few decades. It felt like a natural move to build this in Germany. And here we are six months later, having designed, assembled and commissioned our first few prototypes in record time. I think that's a testament to the excellence of the German ecosystem.
Robin: What does record time mean? How fast did you go from zero, a design spec sheet, to a robot walking?
Sandor: We originally started as a company focused on the intelligence and the AI layer, we have access to some of the best talent in that space. I was leading a line of research at MIT, and my cofounder Maurice Rahme, with experience at Boston Dynamics, was very obsessed with manipulation and with what was required to get these robots to do well in the environments we were proposing, specifically the energy sector and public safety. That's always been the focus.
With regard to the stack, we decided we were going to go full-on vertical in February. From then on, things went very quickly. Most of the spring was spent on design. Most of the summer was assembling, fixing bugs and errors, commissioning the robot. We overcame failures on the legs, the knees, the hips, much the same things that human joints tend to fail with as well.
During the month of August, we shipped our entire team to Germany. Everybody was living in a garage, working from about 3:00 PM until 3:00 AM, and then we'd take turns with some of our suppliers, who would fix the errors in the morning. We ran those daily cycles, and on weekends, for about a month. That was the fastest commissioning my cofounder and I have ever seen in our lives for any robot.
Robin: We love to back people who are thinking about bringing the software speed of development into hardware. What kinds of companies are you doing pilots with, and what are the use cases?
Sandor: We're operating in two verticals. One is with governments, focused on public safety. There are a number of incidents around airports throughout the world, and financial centers, where there's a suspicious backpack, a suspicious car, a suspicious drone left behind or intruding on the airspace. Germany had some recent examples in August 2026.
These are situations where you'd normally put on a bomb suit and approach the device with your tracked vehicle—and those tracked vehicles haven't really changed much since the '70s. They're the tenth generation of the same thing. You have some degree of grasp over what the robot does and it's more intuitive than it used to be, but you still have to effectively wear the bomb suit and go in manually. That manual approach, which is the term they use in explosive disposal, is what we're trying to eliminate entirely, so that there's no human life at risk.
That manual approach, which is the term they use in explosive disposal, is what we're trying to eliminate entirely, so that there's no human life at risk.
In oil and gas, it's really about autonomous inspection rounds and making sure we can map and safely operate the assets of our partners. And then whenever there's an anomaly, or something is sensed outside the threshold, say some pipes in Oklahoma, midstream, and we see vibration or heating or corrosion, we detect it and can actually do something about it with the humanoid.
With all the previous robots, what you had to do is sense that there's an anomaly, flag it in the system, and then somebody physically has to come out. This can happen on Christmas Day, or Thanksgiving, and you have to have these people ready to go and fix these problems. Yet, it's a pretty basic fix that these robots will be able to carry out autonomously with time. At the moment, we do all of this with human supervision in place. Eventually, we see the future as one human supervisor overlooking a fleet of robots and managing that fleet before full autonomy.
Robin: Many people have different opinions on humanoids. Why the human form factor?
Sandor: Good question…
Robin: …Not the first time you've been asked.
Sandor: Absolutely not. But to be honest with you, I do agree with a lot of the criticism that general-purpose humanoids get. The reason is that humans aren't general purpose either. I'm not a great chef in the kitchen. I'd need specific training to be able to make certain types of cakes. If I were to go onto an oil and gas rig, I'd need to go through training as well, and more than that, I'd have to wear personal protective equipment appropriate to that environment: a hard hat, high-vis, anti-corrosion gear, a sensor to monitor the gas levels around me.
We have people who specialize in work around the home, like gardeners and cleaners, and others who work in offshore oil and gas. It just happens that offshore jobs are some of the most dangerous on the planet, and we felt they're much more ripe for automation. These giant metallic structures in the middle of the ocean were built for humans, and now we're putting humanoids on them. Literally every single gauge, every single pipe, every single valve and lever has been designed with human height and force in mind.
Robin: That's also what resonated with us when we did the investment, even though a lot of people on our team were quite skeptical about the humanoid form factor. Your robot is called Roger. How did you pick the name?
Sandor: There was a friend of ours who hosted us in the early days in the UAE, as we were doing some go-to-market work and demonstrations there. He was called Roger, and we wanted to name it after him. Also, in radio lingo they do say, “Roger that.” to confirm successful reception and understanding of a message. We're not actually taking the human out of the loop, we're enabling the human to do the job from a safe distance.